


Grippy Broom Holder
 Byvc-designLikes0Downloads3.2K
Build another version of this model.
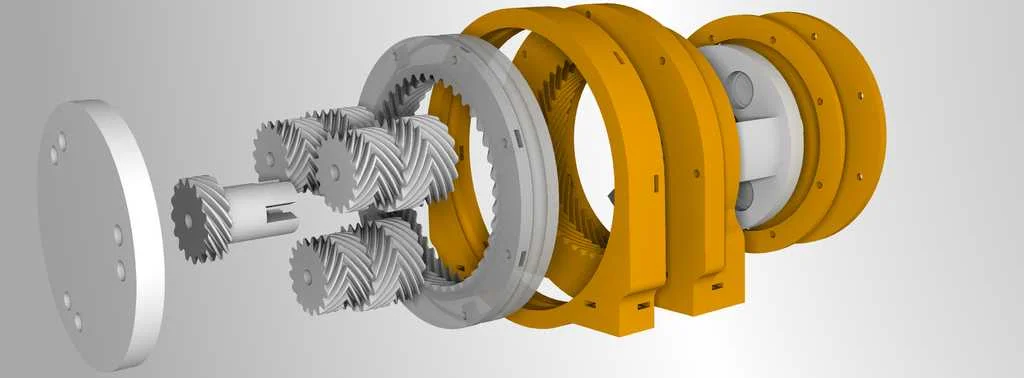
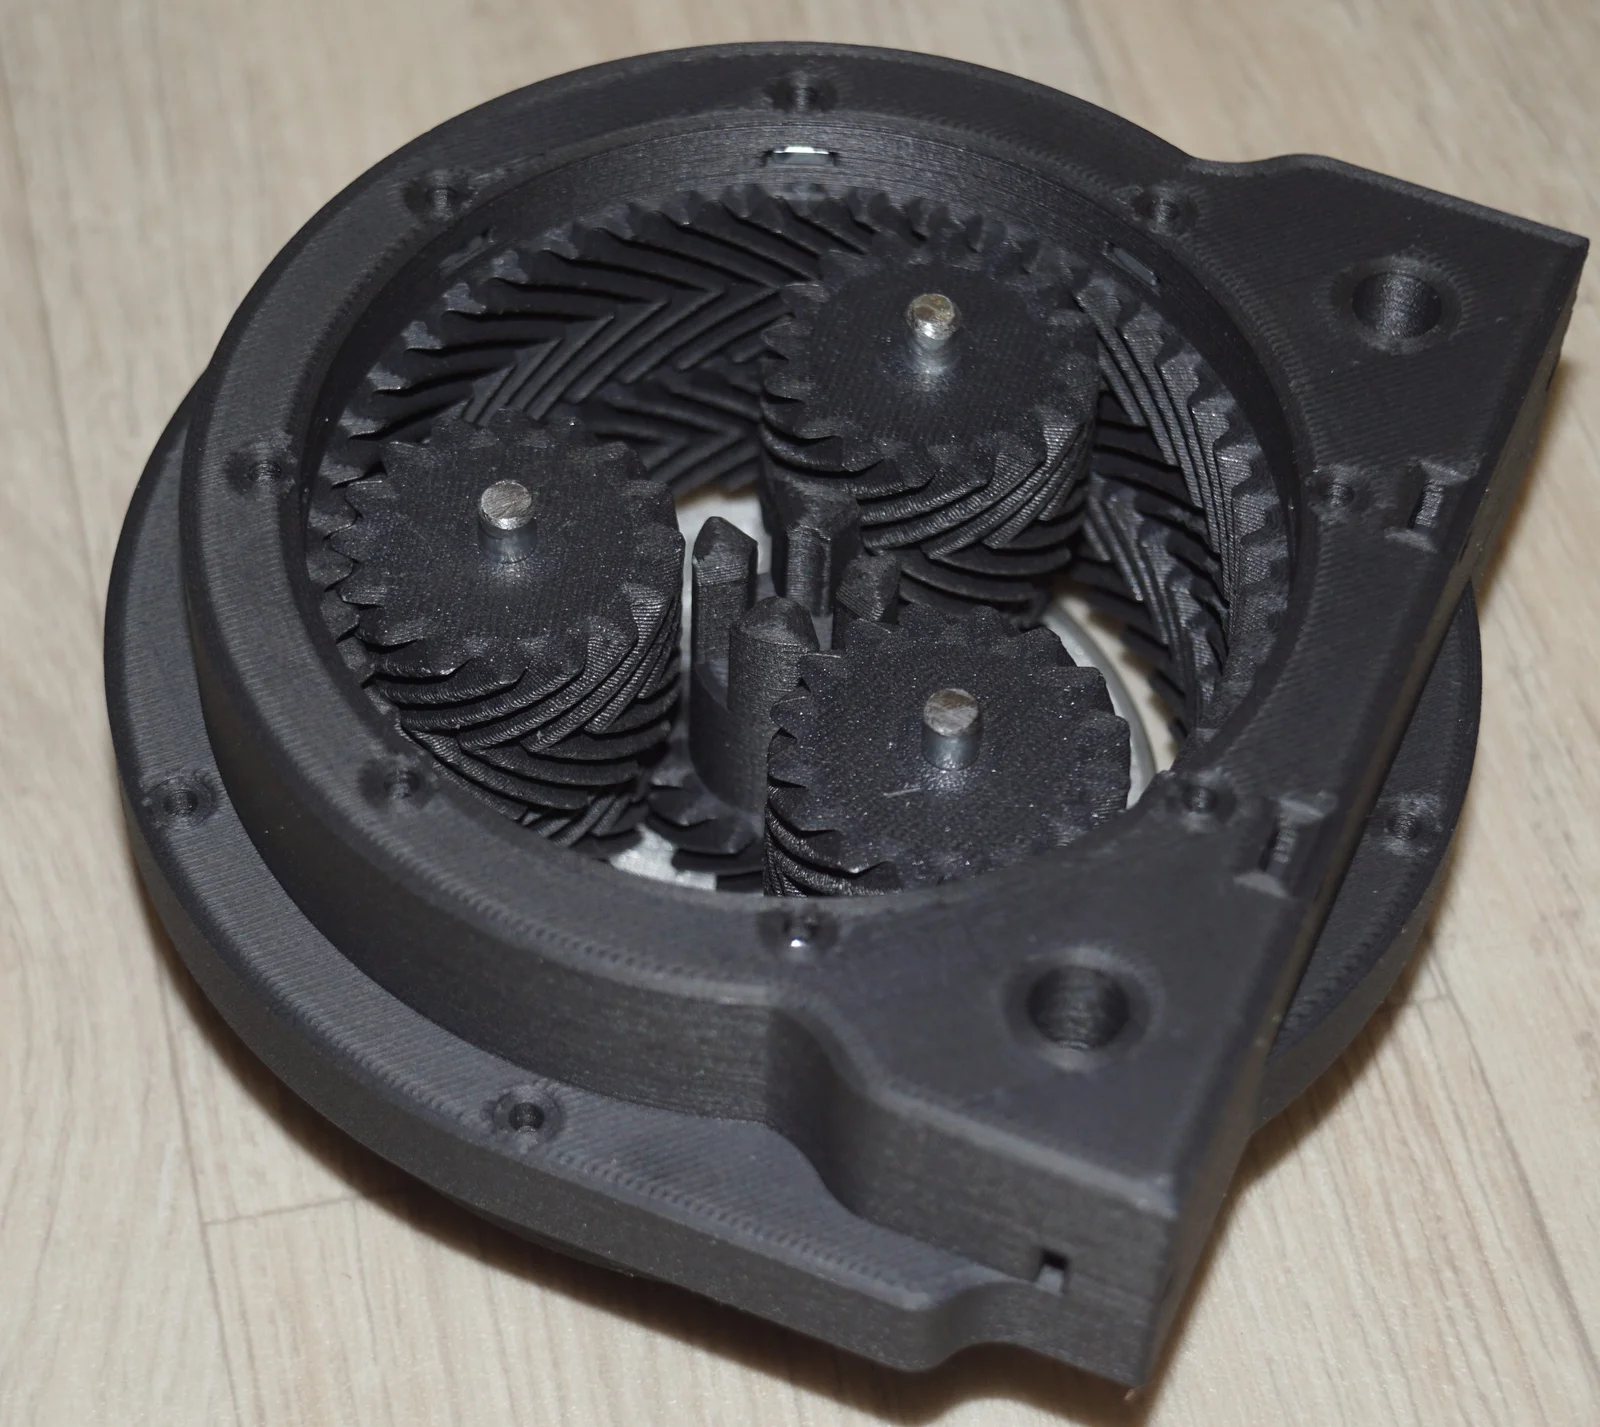
This is my design of split ring planetary gearbox for the shoulder joint of the RR1 Robotic Arm with the reduction ratio of 1:40. It is designed to increase torque of a big Nema 23 stepper motor. The gearbox requires 7 bearings 625 (16x5mm, 2 more oustide bearings are needed if mounted to the robot), 3mm metric screws of various lengths, 3mm square nuts (holes for nuts are prepared), 5mm bolts, and many 6mm bearing balls (G40) for custom ring bearing . I recommend to print gears and rings with carbon fiber filled material like Prusament PC blend with CF. For serious builds I also recommend to fine tune sizes of gears directly in CAD sources.
For CAD sources please see: https://github.com/surynek/RR1
For the RR1 Robotic Arm project please see: https://hackaday.io/project/185958-rr1-real-robot-one-a-diy-desktop-robotic-arm and https://surynek.net/_main/index.php?select=research#RR1rev2
Byvc-designLikes0Downloads3.2K

 BySeppoTakaloLikes960Downloads1.9K

 Byrb_200934Likes48Downloads1.1K

 ByZED4EverLikes313Downloads5.2K

 Byadvanced-hobby-labLikes0Downloads288

 ByfifindrLikes500Downloads4K

 ByVC_DesignLikes679Downloads3.6K

 ByKNIN_CustomLikes112Downloads437

 ByDan Schwartz SchwartzLikes744Downloads3.4K

 ByUpcrid3D_1585693Likes808Downloads2.1K

 ByWilko_SLOLikes935Downloads2K

 Bychubbs8697_2027893Likes585Downloads1.7K