F3D
Động cơ bước cho rèm tự động tại nhà 1

3 images

Ý Tưởng Khác

Động cơ bước cho rèm tự động tại nhà

By Titafubaki

Downloads
264
Likes
212
Views
3,519
Comments
2

Files 6 1.4 MB

  • 10Gear_1767438974.stlSTL · 73.9 KB
  • Deckel_1767438975.stlSTL · 58.3 KB
  • Case_1767438975.stlSTL · 127.8 KB
  • 24Gear_1767438976.stlSTL · 813.9 KB

Make a variant with AI

Build another version of this model.

Open Studio

Description

Material List:

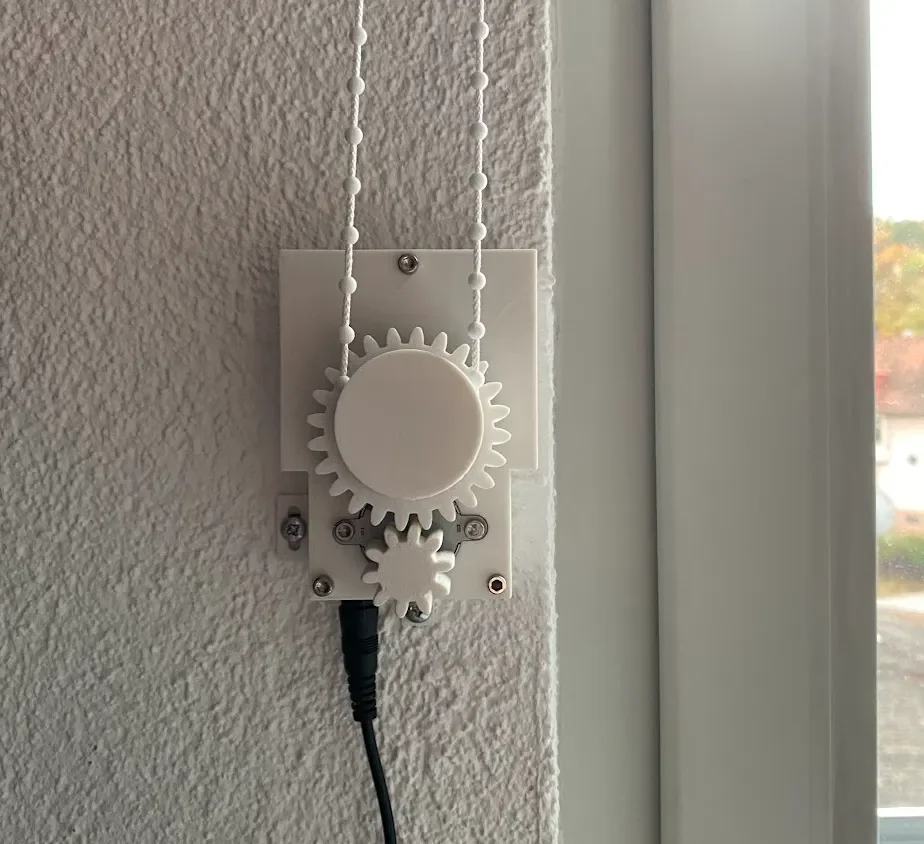
  • 1x 28BYJ-48 (5V)
  • 1x Stepper driver board uln2003
  • 1x NodeMCU
  • 1x 608rs bearing
  • 1x M8 x 16mm bold
  • 1x Powersupply 5v
  • 2x Screws and dovel to mount it to the wall
  • 9 - 13x M3 x 10mm Screw
  • 2x M3 Nut

I did use a universal PSU with 30W and was put the Voltage to 6V You can even go up to 9V but when you connect the NodeMCU make sure to use the VIN Connector.

I use ESPHome with this configuration


api:
  encryption:
    key: "****"
  services:
    - service: control_blind
      variables:
        target: int
      then:
        - stepper.set_target:
            id: my_stepper
            target: !lambda 'return target;'
        - sensor.template.publish:
            id: position
            state: !lambda 'return target;'

cover:

  • platform: template
    name: "Wohnzimmer"
    id: my_blind
    device_class: shade
    position_action:
    • stepper.set_target:
      id: my_stepper
      target: !lambda 'return -52000 +(int(52000 * pos));'
    • sensor.template.publish:
      id: position
      state: !lambda return id(my_stepper).current_position;
      open_action:
    • stepper.set_target:
      id: my_stepper
      target: 1 # Set the target position for fully open (0 steps)
    • sensor.template.publish:
      id: position
      state: !lambda return id(my_stepper).current_position;
      close_action:
    • stepper.set_target:
      id: my_stepper
      target: -52000 # Set the target position for fully closed (-52000 steps)
    • sensor.template.publish:
      id: position
      state: !lambda return id(my_stepper).current_position;
      stop_action:
    • stepper.set_target:
      id: my_stepper
      target: !lambda 'return id(my_stepper).current_position;'
    • sensor.template.publish:
      id: position
      state: !lambda return id(my_stepper).current_position;
      optimistic: true
      assumed_state: true
      has_position: true

sensor:

  • platform: template
    name: "Wohnzimmer Position"
    id: position
    update_interval: 1s
    lambda: |-
    return id(my_stepper).current_position;

stepper:

  • platform: uln2003
    id: my_stepper
    pin_a: D1
    pin_b: D2
    pin_c: D5
    pin_d: D6
    max_speed: 500 steps/s
    sleep_when_done: true

    Optional:

    acceleration: inf
    deceleration: inf
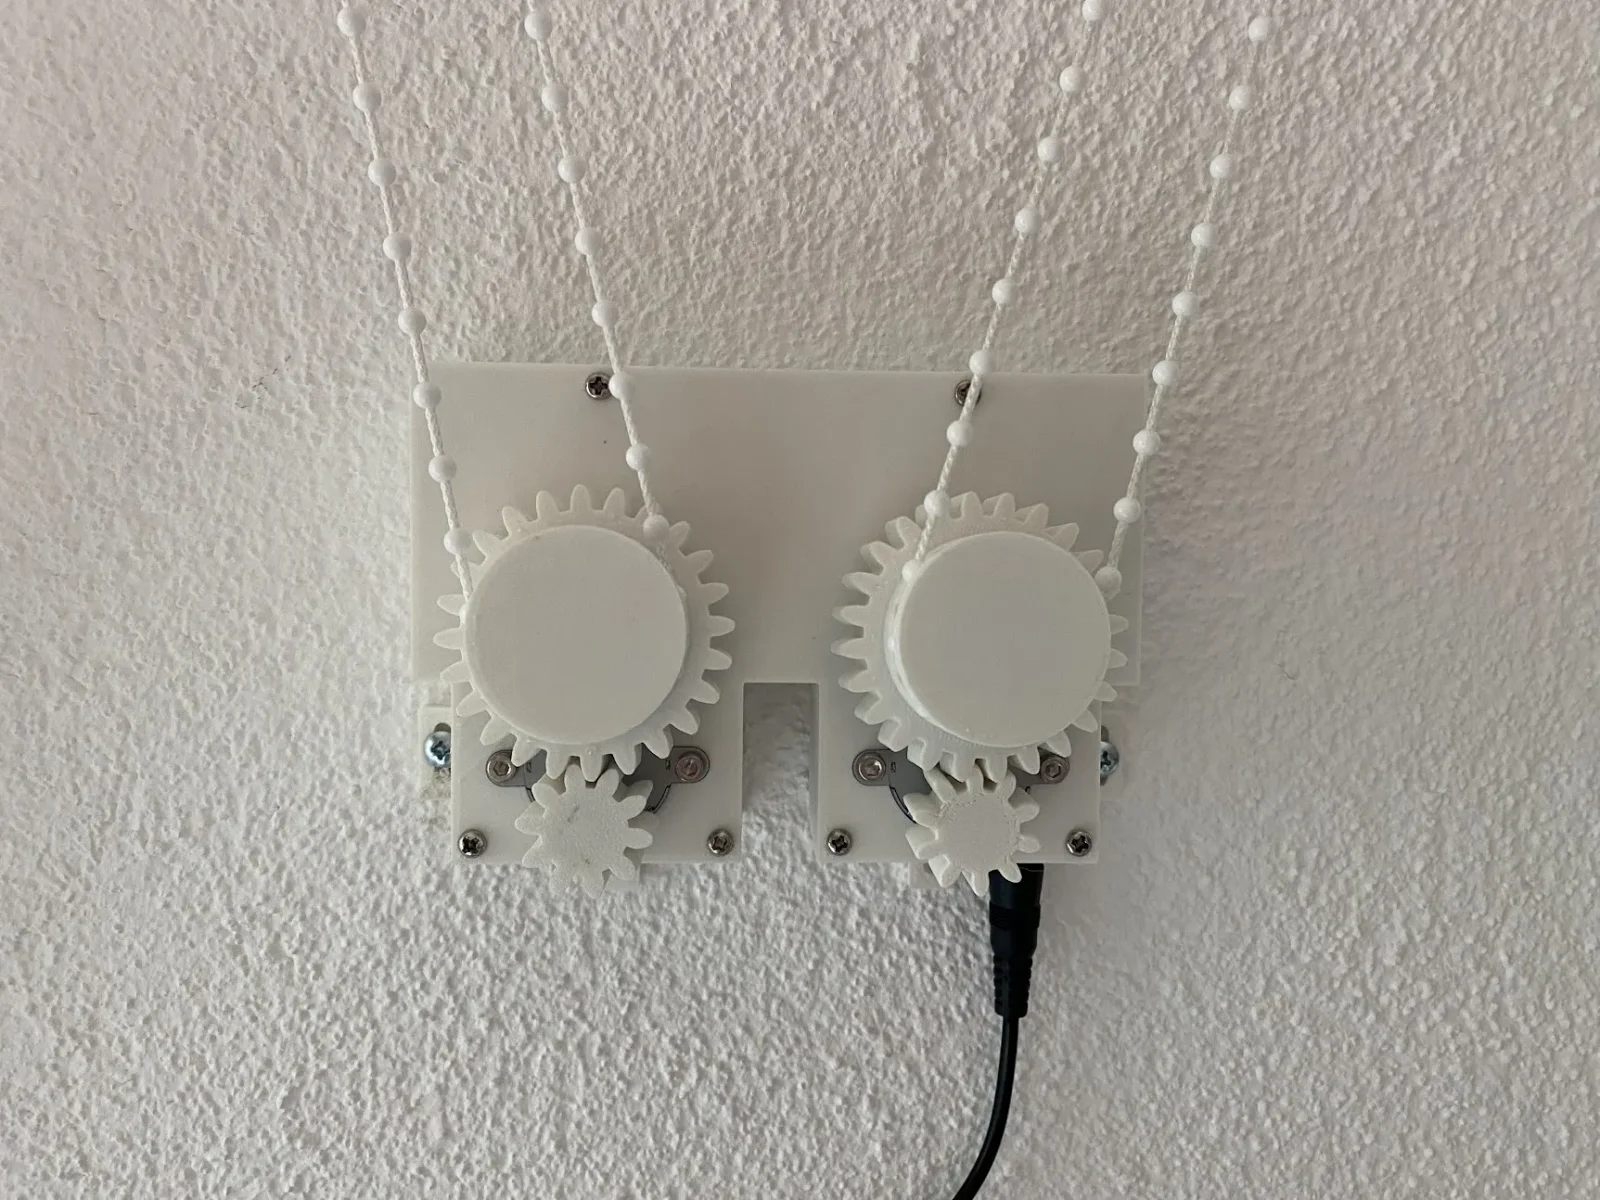
    The 52000 in the code is the steppes needed to go all the way down. This you have to figure out yourself for your window. For windows that are right next to each other there is a 2x version so you only need to use one NodeMCU.

Read more Show less

Print spec

Formats
stl
Model files
6
Total size
1.4 MB
Largest file
813.9 KB

2 comments

See all