



Bộ sưu tập 11 nhân vật mô hình Mecca Chameleon in 3D vui nhộn
 ByZED4EverLikes313Downloads5.2K
Build another version of this model.
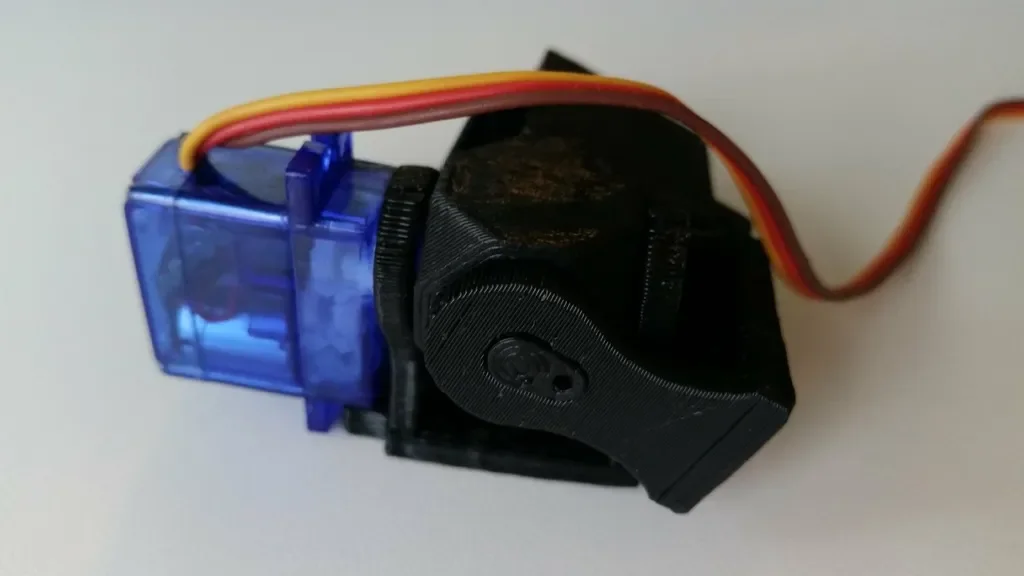
I designed this universal joint from scratch, with the idea to use it in the shoulder / hip joints of a robot dog I´m working on. (I hope I upload that soon too).
My main motivation was to get a universal joint with two DoF in one place, since that is what we mammals have in out shoulders and hip.
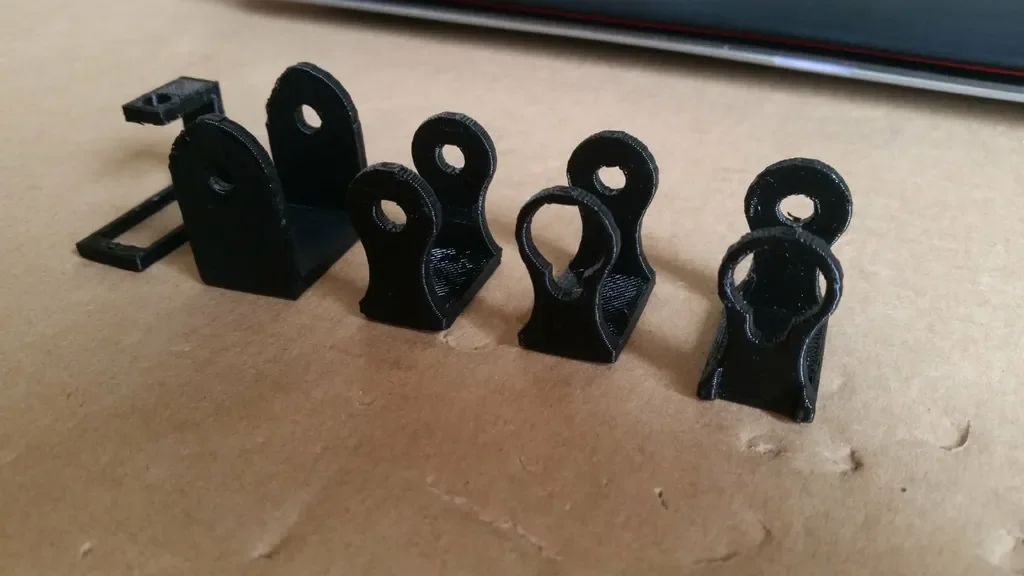
You'll see the design steps I wen though to get to were I am now. It is designed to fit the Tower Pro 9g micro servos
I know the print quality is not the best, sorry for that. The parts were printed with a cheap plastic (that looks like never ends!)
I'll upload new pictures as soon as I print with another (better) PLA.
Supports:
No
Notes:
You'll need to print:
* 2 Arch * 2 Axis * 1 Core
Assemble instructions
To assemble this Servo based universal joint you should follow this steps:
Category: Robotics
ByZED4EverLikes313Downloads5.2K

 ByprofessorbootsLikes0Downloads288

 ByleonicLikes0Downloads1.4K

 ByfifindrLikes500Downloads4K

 BymoonyxLikes0Downloads701

 ByVC_DesignLikes679Downloads3.6K

 ByDan Schwartz SchwartzLikes744Downloads3.4K

 Byvc-designLikes0Downloads3.2K

 Bythorin-oakenshieldLikes0Downloads536

 Bytorii-creative-studioLikes0Downloads452

 ByUpcrid3D_1585693Likes808Downloads2.1K

 ByshoheiyLikes0Downloads437