


Pocket-Size Third Hand Mini Spring Loaded Vise
 ByrjunLikes0Downloads306
Build another version of this model.
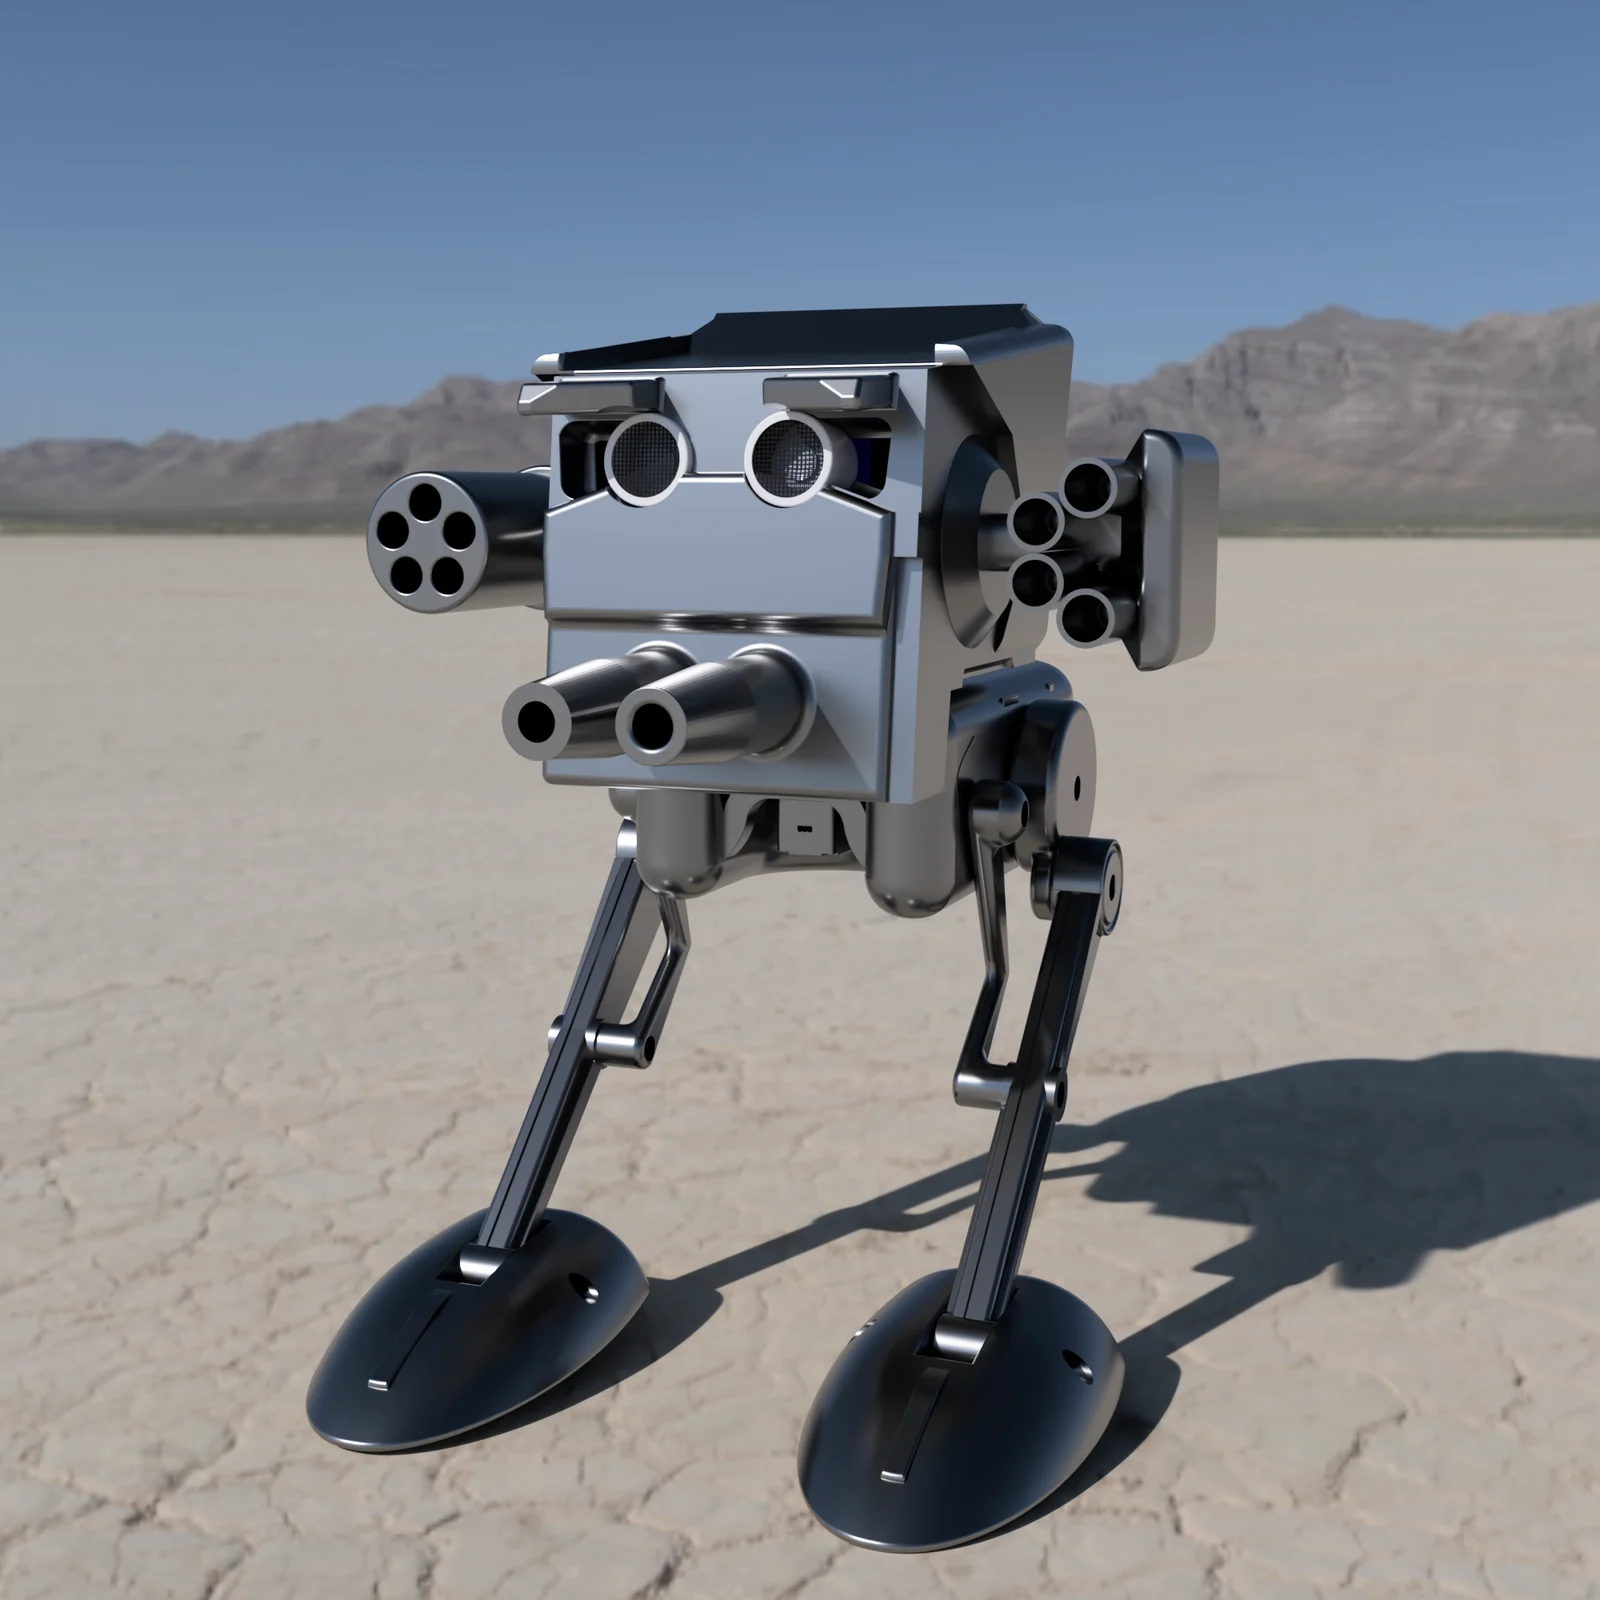
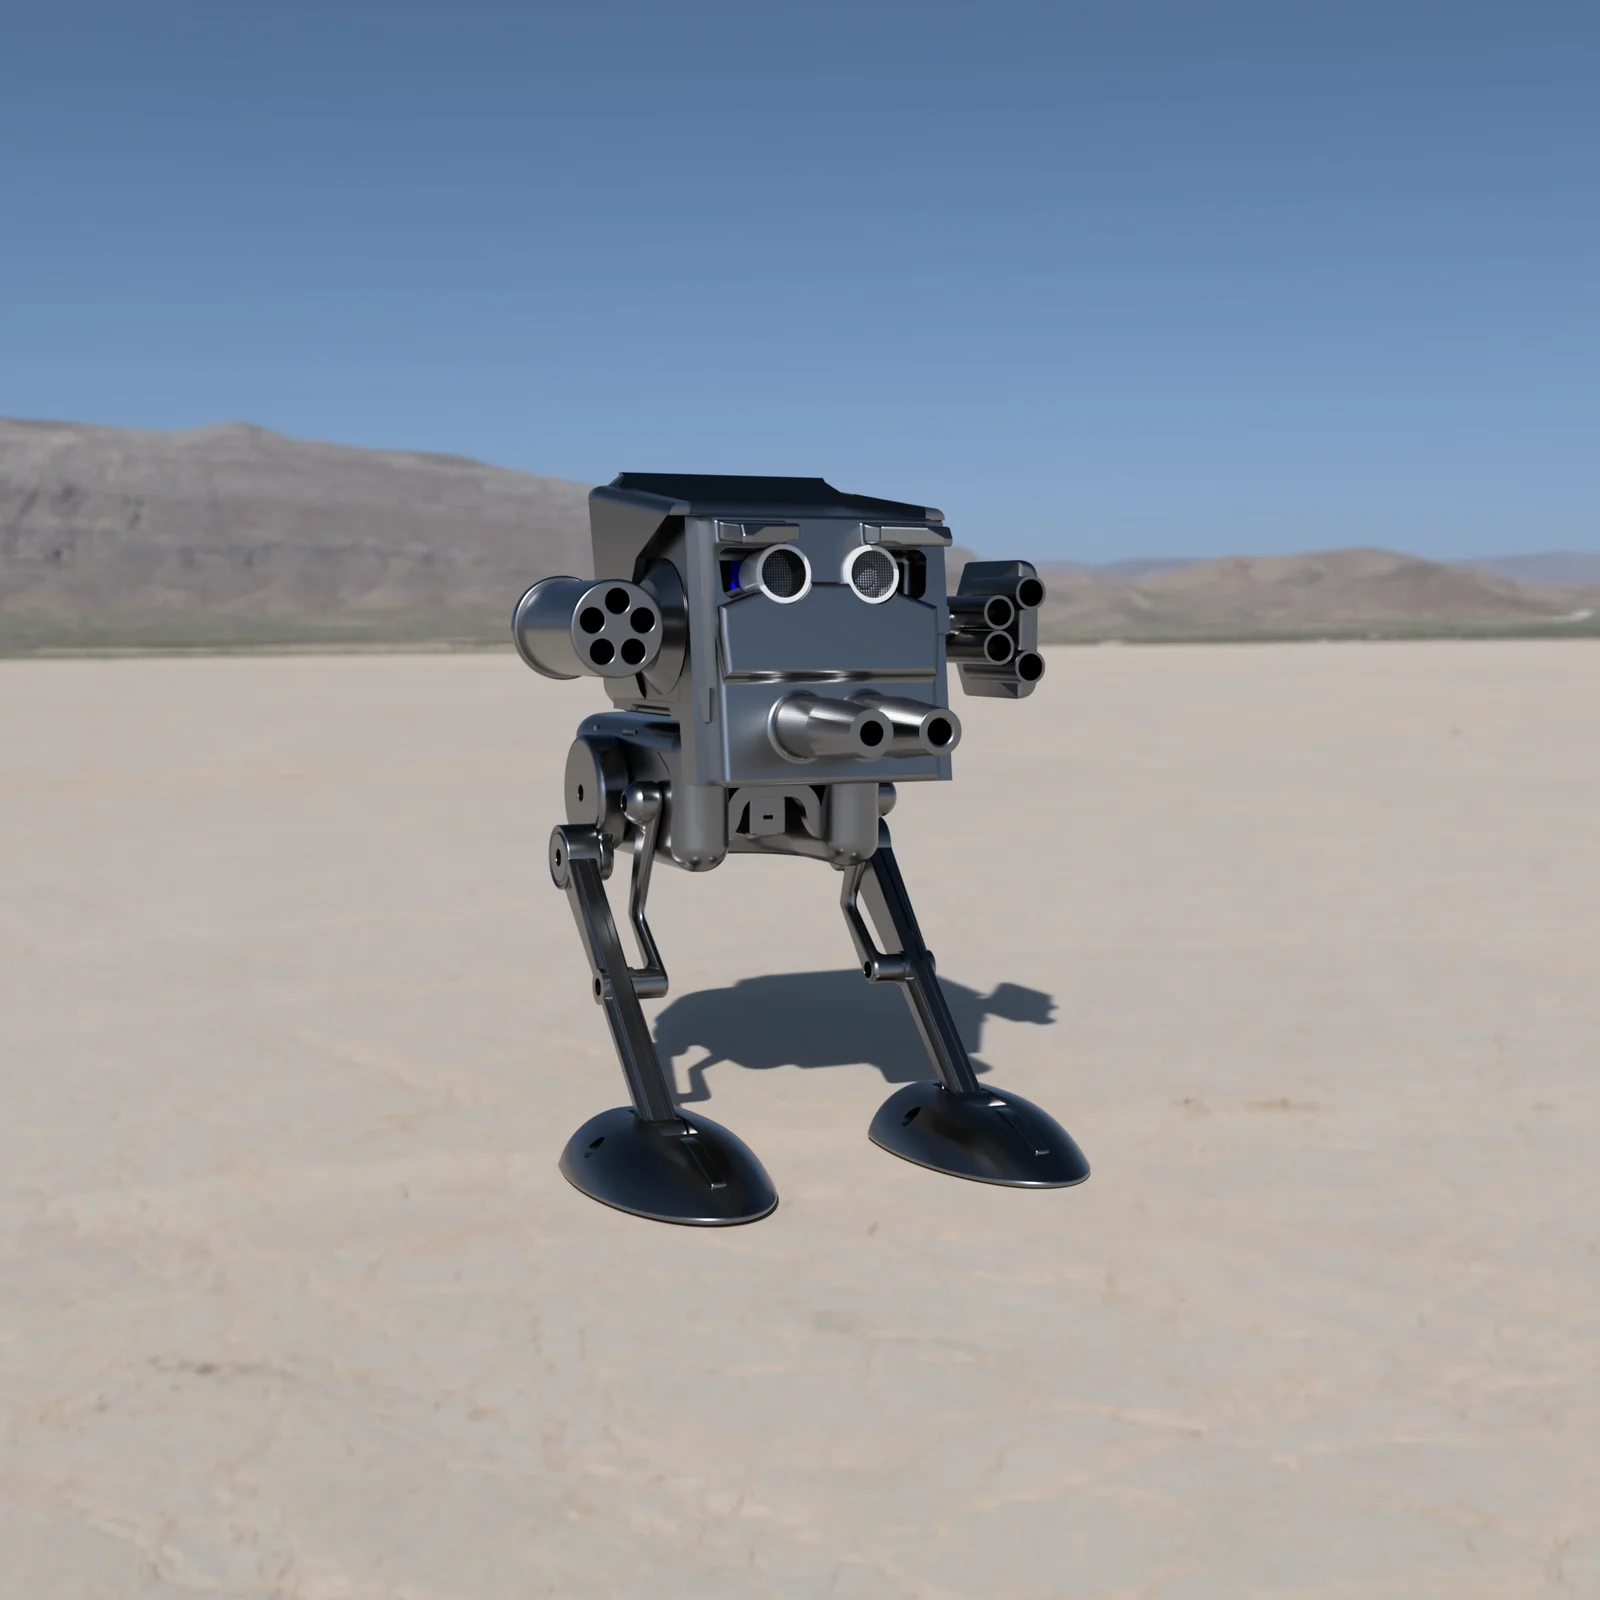
Introducing the HP Otto AT-ST
🧩 What This Module Does
Encases the HP Otto in a fun and immersive body
Lets Otto perform walking, stepping, and head panning movements
Great for STEM challenges, robotics lessons, or just giving your robot a new personality
🔧 How It Works
After Printing all the parts, Assemble the lower body and install the two servos for the leg movement.
Use 2x Motor Cross pressed into the "Cam x2" printed part, this will drive the linear motion.
With the Parts assembled you can add the final servo for the head, and ensure each servo wire is sticking out.
Attach the Board, and optional "Ultrasonic" Eyes for aesthetics
Connect the two servos for the legs, and head servo, noting the output of the port on the board. (this will be important for programming later)
The mechanism converts servo rotation into a walking linear motion
No soldering—just print, assemble, and plug into the Invent ports
📦 What You Need
Print Settings
Following prints with at least 4 walls and 22% infill to ensure strength:
Long link x2
Link x2
Cam x2
Turret pin (x10)
Remaining prints with atleast 4 walls:
Foot x2
BOTTOM BODY
Head
Caution:
This is V1 so please be patient as I print and check tolerances.
please check back for updated print files
I hope to have code programed for it by the end of the contest date, but any help would be appreciated as coding is not something I am entirely familiar with.
Door for the head needs to be re-worked and will be updated shortly
Designed the motion using Linkage and mimicked a Hoeken example rotated and modified slightly, trying to following a single linear path for the legs to move on.
Please comment any issues or design changes that would help!
Cheers!
ByrjunLikes0Downloads306

 ByleonicLikes0Downloads1.4K

 ByZED4EverLikes313Downloads5.2K

 Byreinvent3dLikes0Downloads135

 ByfifindrLikes500Downloads4K

 Bymrfixit_324954Likes65Downloads478

 Bylab-96Likes0Downloads110

 BymoonyxLikes0Downloads700

 ByVC_DesignLikes679Downloads3.6K

 ByDan Schwartz SchwartzLikes744Downloads3.4K

 ByBrokentooth_designsLikes83Downloads455

 Byvc-designLikes0Downloads3.2K