



Marci's Mount - Ngàm in 3D cho kính thiên văn Hadley
 ByMarciLikes87Downloads297
Build another version of this model.
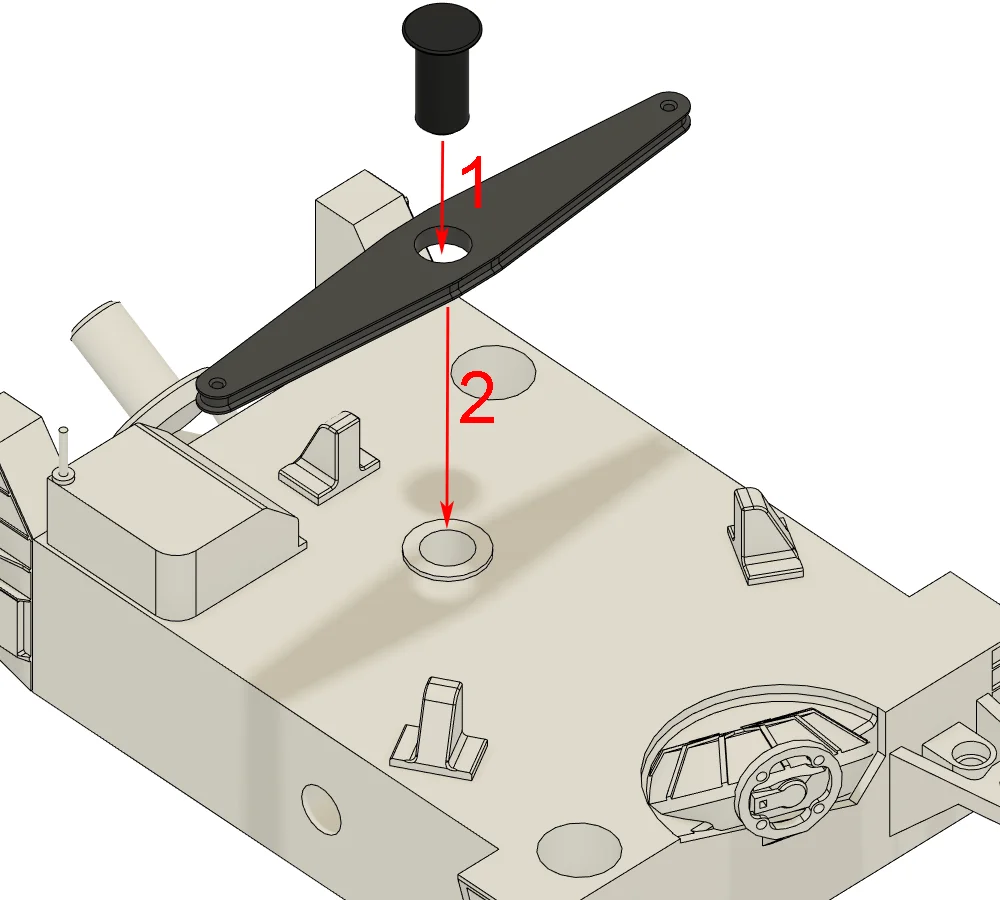
Download the list of objects to print and the assembly .pdfs guides and get started!
This model is the original one with an addition by brenagwynn (github), the rsm_base_unofficial part, which was missing in the main object.
--------------
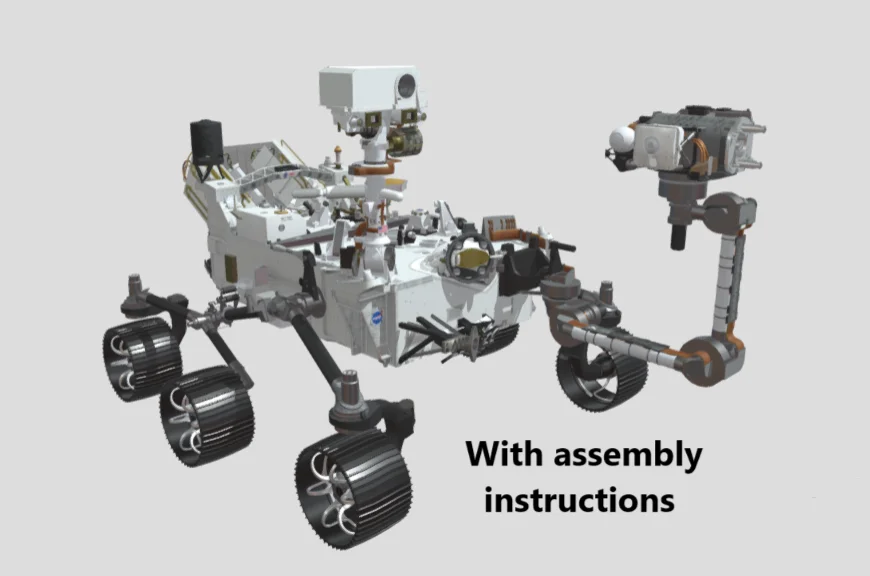
Perseverance, nicknamed Percy, is a car-sized Mars rover designed to explore the Jezero crater on Mars as part of NASA's Mars 2020 mission. It was manufactured by the Jet Propulsion Laboratory and launched on July 30, 2020, at 11:50 UTC. Confirmation that the rover successfully landed on Mars was received on February 18, 2021, at 20:55 UTC.
Perseverance has a similar design to its predecessor rover, Curiosity, although it was moderately upgraded. It carries seven primary payload instruments, nineteen cameras, and two microphones.
The rover also carried the mini-helicopter Ingenuity to Mars, an experimental technology testbed that made the first powered aircraft flight on another planet on April 19, 2021.
The rover's goals include identifying ancient Martian environments capable of supporting life, seeking out evidence of former microbial life existing in those environments, collecting rock and soil samples to store on the Martian surface, and testing oxygen production from the Martian atmosphere to prepare for future crewed missions.
— Wikipedia
Author/Origin/License: NASA Jet Propulsion Laboratory, Public Domain
ByMarciLikes87Downloads297

 Bystrifu_4061046Likes151Downloads1.3K

 ByBoonby_1059917Likes659Downloads1.2K

 ByTheodeGuzman_3135033Likes2Downloads14

 ByFabianVeileLikes414Downloads1.5K

 BygillisLikes121Downloads2.1K

 ByLat0102_256421Likes35Downloads141

 Byloykastj_145194Likes1Downloads65


 ByzoltanfLikes73Downloads279

 Byleizerdesign_249154Likes62Downloads803

 ByHonzalLikes246Downloads182