


Ngăn Kéo Đa Năng Lắp Ghép Modular
 ByWilko_SLOLikes935Downloads2K
Build another version of this model.
How to build it -----> youtube.com/watch?v=2WKWtY56g3k <-----How to build it
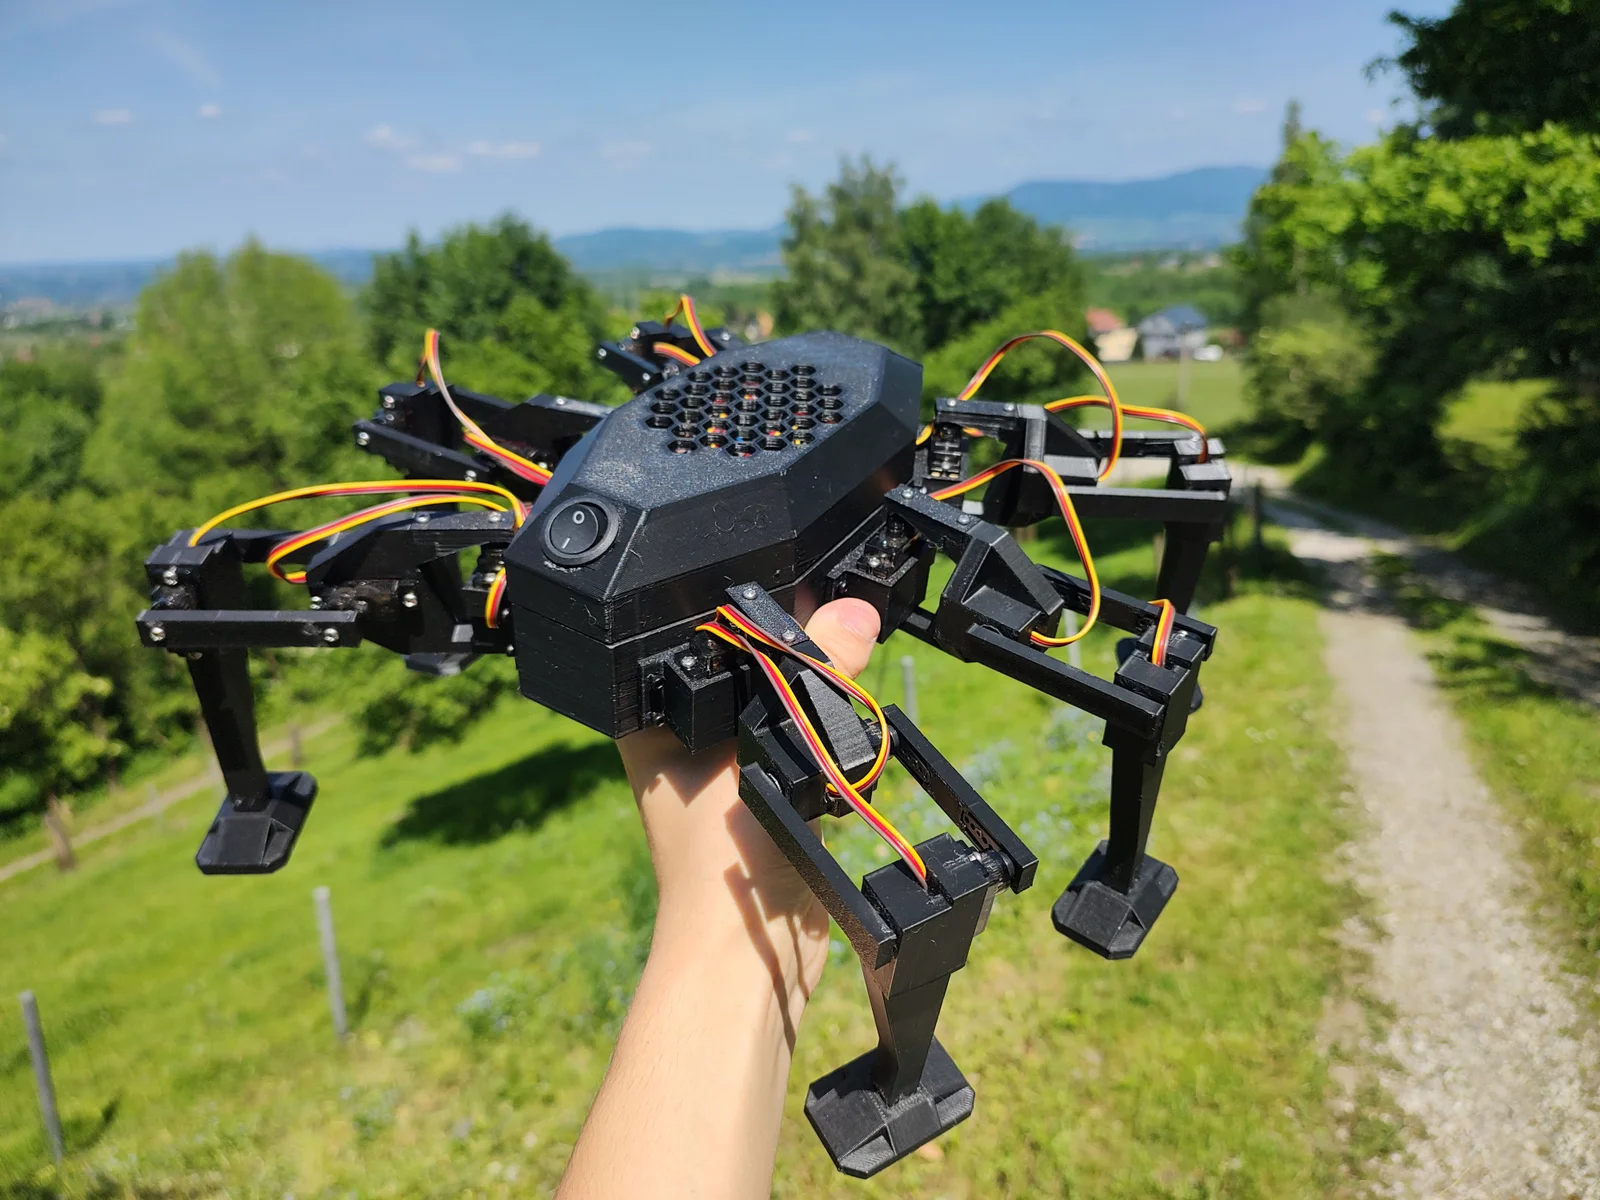
This project showcases a robust 6-legged robot (hexapod) powered by an ESP32 microcontroller and dual PCA9685 servo drivers communicating over a stabilized I2C bus. Real-time locomotion is driven by the ultra-low latency CRSF (ExpressLRS) RC protocol. The control layout is optimized for intuitive piloting: the right stick handles linear forward/backward movement and body rotation (Roll), while the left stick controls dedicated sideways crab-walking (Yaw) and dynamic ride height adjustment.
I used RadioMaster boxer to control my robot, but you can you any 2.4ghz radio.
To eliminate massive current spikes and voltage drops caused by 18 servos acting simultaneously under load, the electronics utilize a dedicated dual-power rail design. A high-power XL4016 buck converter (8A) powers the ESP32 logic and the left bank of servos, while a secondary 5A buck converter is dedicated solely to the right bank. The custom firmware features 3 software-optimized gaits (fast Tripod, organic insectoid Wave, and an ultra-stable creep/Ripple gait where 5 legs always maintain ground contact), alongside a hardware ARM/DISARM safety switch and an instant self-centering function.
Parts you need:
MPU6050
2x PCA9685
ESP32 DevKit
18x 623zz ball bearings
ELRS 2.4GHz reciver (only if you own an ELRS radio)
2x 5A step down
18x mg90s servo
https://www.aliexpress.com/item/1005007830491580.html?spm=a2g0o.order_list.order_list_main.50.531a1802FFnylY M2.5 heat inserts and screws kit (I recommend this one)
12V Round Rocker Switch
2x 18650 battery
DuPont wires, xt60 connectors, glue....
ByWilko_SLOLikes935Downloads2K

 ByWolf_115355Likes513Downloads8.4K

 ByZED4EverLikes313Downloads5.2K

 ByfifindrLikes500Downloads4K

 ByVC_DesignLikes679Downloads3.6K

 ByDan Schwartz SchwartzLikes744Downloads3.4K

 Bydona3d_Likes456Downloads674

 ByUpcrid3D_1585693Likes808Downloads2.1K

 ByBrokentooth_designsLikes83Downloads447

 Bychubbs8697_2027893Likes585Downloads1.7K

 Byquibeck_3353173Likes965Downloads1.9K

 BySeppoTakaloLikes960Downloads1.9K